Differential-drive AGV navigation stack
A public differential-drive simulation with EKF localisation and Nav2. Clean-clone verified; versioned release and public demonstration pending.
stack ROS 2 Jazzy · Nav2 · robot_localization (EKF) · ros2_control · Gazebo Harmonic
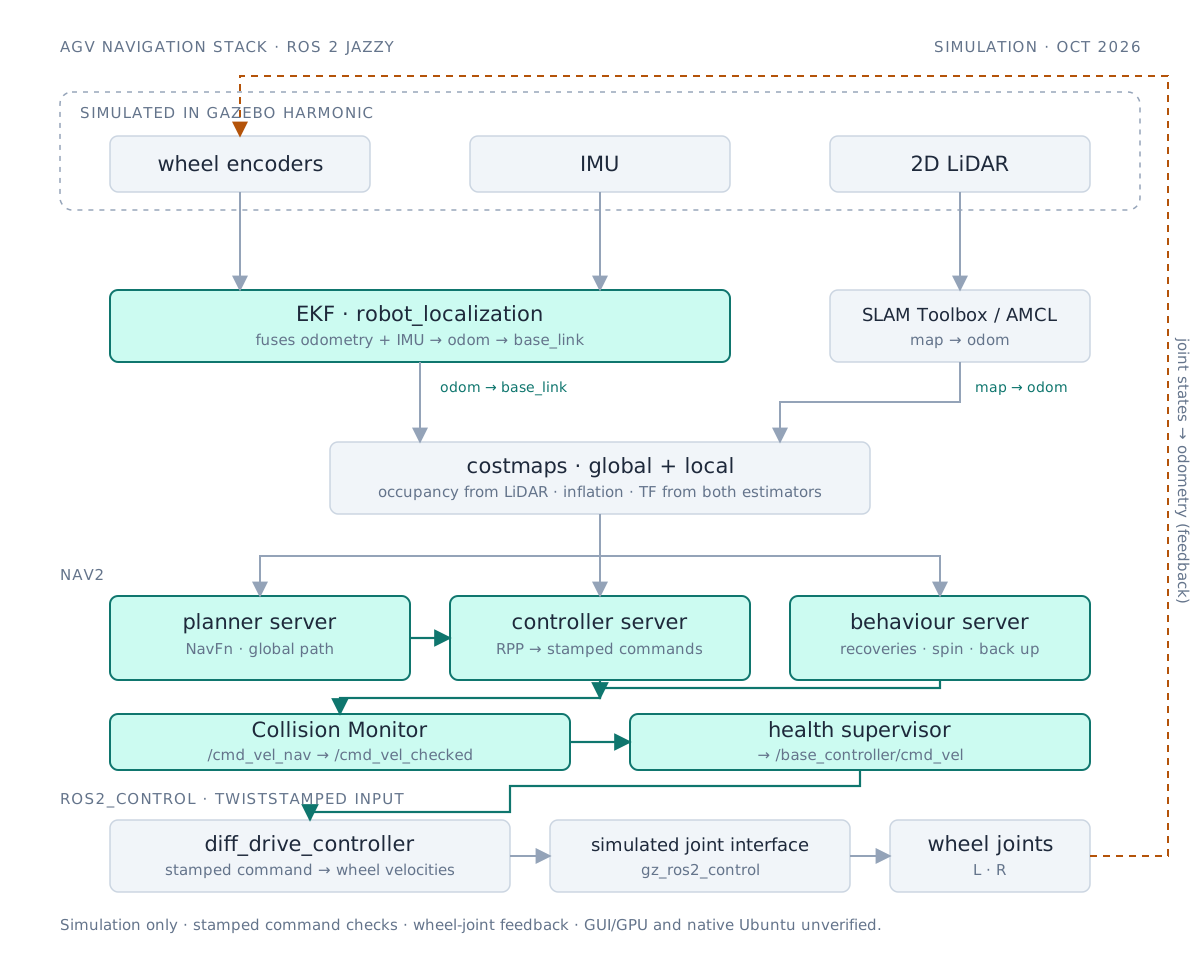
What it demonstrates
- State estimation — EKF fusion of wheel odometry and IMU, and what actually degrades it: wheel slip, unmodelled latency, covariance that is guessed rather than measured.
- Planning and control — global planner and local controller behaviour on a non-holonomic base, and the recovery behaviours that decide whether a robot is usable or merely demonstrable.
-
ros2_controlintegration — a simulated joint interface throughgz_ros2_control, with stamped commands checked by Collision Monitor and health supervision. - Reproducibility — clean-clone verification passed on 13 October 2026: three packages built, seven tests passed and a contact-free clear route.
Build log
- 09 Oct 2026 Headless WSL2 environment — ROS 2 Jazzy + Gazebo Harmonic
- 10 Oct 2026 URDF + ros2_control simulated joint interface
- 10 Oct 2026 EKF wheel-odometry / IMU fusion
- 10 Oct 2026 Saved map + AMCL localisation
- 10 Oct 2026 Costmaps + NavFn / Regulated Pure Pursuit navigation
- 10 Oct 2026 Simulation benchmarks — 30/30 nominal goals, zero obstacle contacts
- 13 Oct 2026 Clean-clone verification + licence and maintainer metadata
- 13 Oct 2026 Public repository available — agv-ros2-sim
- Next Versioned release + public demonstration / artefact publishing current
Status as of 24 November 2026. Latest recorded verification: 13 October 2026. Public source → Versioned release and public demonstration remain pending.